Hold infinity
in the palm of your hand
And eternity in an hour.
把无限握在掌心,
将永恒凝于一瞬。
無限をその掌に、
永遠をひとときに。
William Blake · Auguries of Innocence威廉·布莱克 ·《天真的预言》ウィリアム・ブレイク · Auguries of Innocence

Yecheng Zhang 张业成

I am a Ph.D. student at the School of Architecture, Tsinghua University.

My research focuses on building-scale urban analytics and simulation, LLM/VLM post-training, evaluation and alignment, and multi-agent systems.

我是清华大学建筑学院博士生。

研究方向包括建筑尺度城市分析与模拟、大模型后训练、评测与对齐和多智能体系统。

清華大学建築学院の博士課程に在籍しています。

研究分野は建築スケール都市分析・シミュレーション、LLM/VLMの事後学習・評価・アライメント、マルチエージェントシステムです。

Yecheng Zhang
More about my work更多研究介绍研究について

I build large-scale urban datasets, evaluate generative AI for scientific discovery, and develop open-source research systems. See my Google Scholar profile for current citations.

致力于构建大规模城市数据集,评估生成式AI的科学发现能力,并开发开源研究系统。当前引用情况见 Google Scholar。

大規模都市データセットを構築し、科学的発見のための生成AIを評価するとともに、オープンソース研究システムを開発しています。最新の引用状況は Google Scholar を参照してください。

BUILDING-SCALE URBAN ANALYTICS & SIMULATION

Buildings are the basic cells of urban systems.

I connect building engineering with urban science through data foundations, generative AI, and bottom-up simulation.

01 · Unified modelingConnect semantic depth at the building scale with geographic breadth at the urban scale.
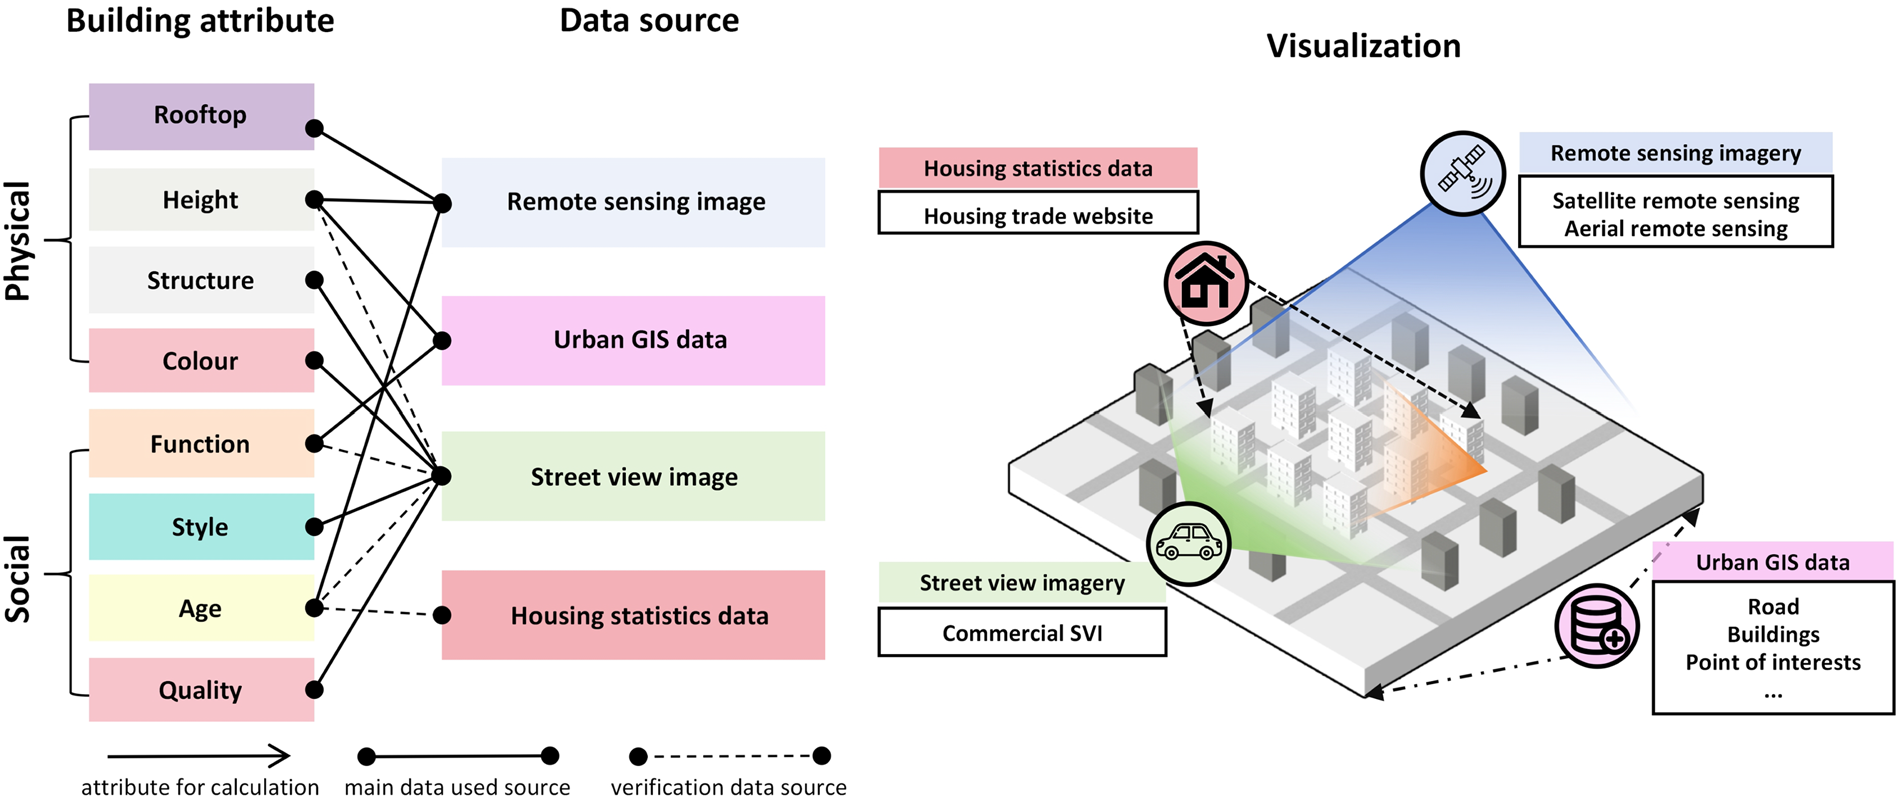
02 · Data foundationsBuild comprehensive, AI-enhanced building datasets with full spatial and temporal coverage.
03 · Generative diagnosisUse generative AI to evaluate building quality, performance, and urban efficacy.
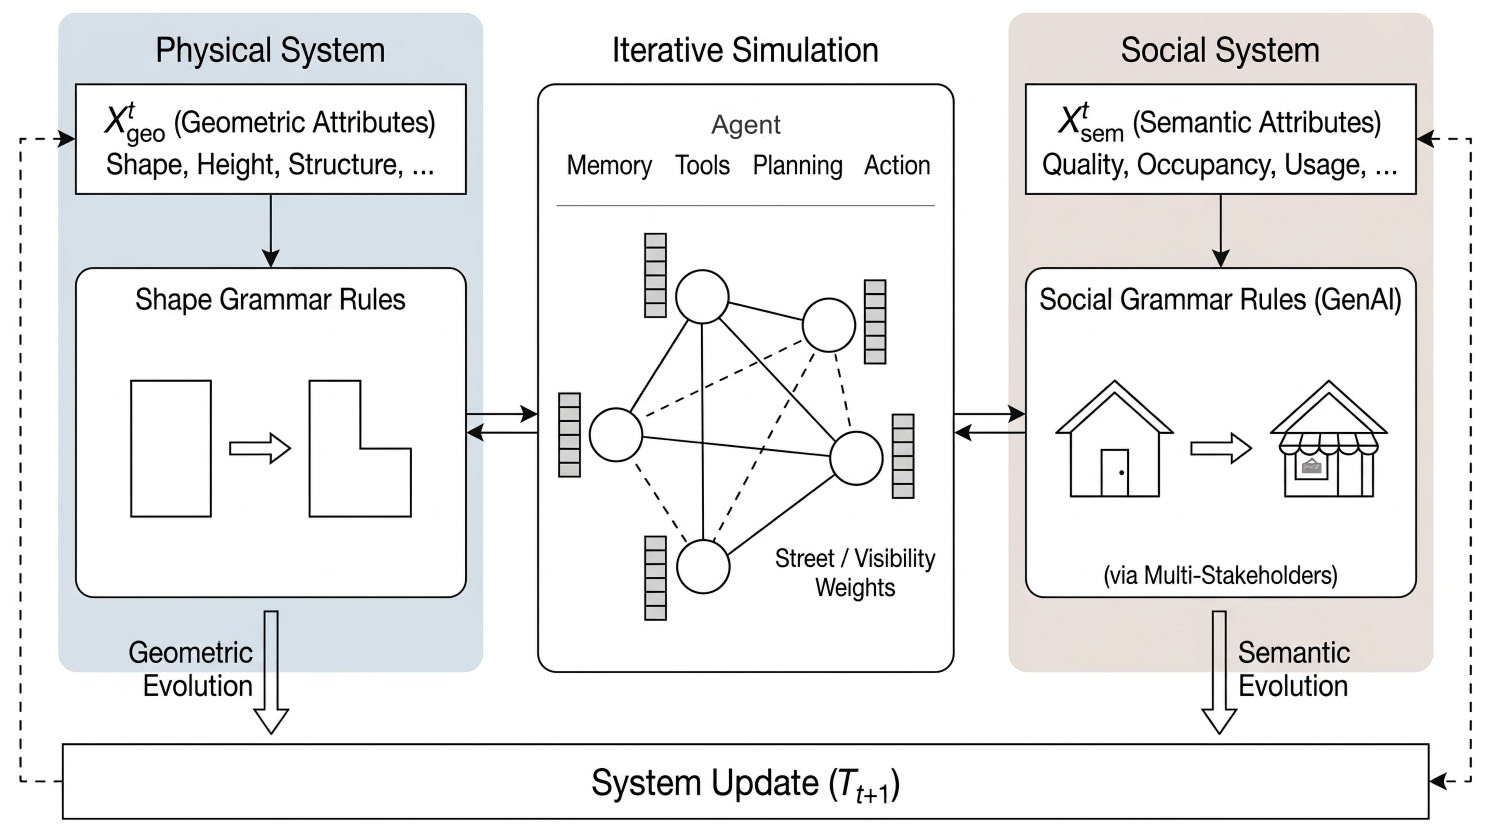
04 · Bottom-up simulationCombine AI and generative rules to model morphological and behavioral transformations.

建筑尺度城市分析与模拟

建筑是城市复杂系统的基本细胞。

通过数据底座、生成式人工智能和自下而上的模拟,连接建筑研究的语义深度与城市科学的地理广度。

01 · 统一建模衔接建筑尺度的语义深度与城市尺度的地理广度。
02 · 数据底座借助人工智能构建时空覆盖完整的建筑级综合数据集。
03 · 生成式诊断利用生成式人工智能评估建筑质量、性能与城市效能。
04 · 自下而上模拟结合人工智能与生成规则,模拟城市形态和行为的复杂演化。

建築スケール都市分析・シミュレーション

建築は都市複雑系を構成する基本単位です。

データ基盤、生成AI、ボトムアップ・シミュレーションを通じて、建築研究と都市科学を接続します。

01 · 統一モデリング建築スケールの意味的深さと都市スケールの地理的広がりを接続。
02 · データ基盤AIを活用し、時空間を包括する建築データセットを構築。
03 · 生成的診断生成AIにより建築の品質、性能、都市効果を評価。
04 · ボトムアップ・シミュレーションAIと生成ルールを組み合わせ、形態と行動の変容をモデル化。
Yet what endures
is founded by poets.
然而,长存之物,
由诗人创立。
しかし、長く残るものを
詩人たちが築く。
Hölderlin · Andenken荷尔德林 ·《纪念》ヘルダーリン ·『追想』

Selected writing精选写作執筆記事

Data Generation & Agentic RL for Seed Models

More writing更多写作その他の記事

Where a GPU Job Actually Runs算力任务究竟在哪里运行GPU ジョブはどこで動くのか

A remote terminal is only the beginning. Understand how code versions, scheduling, storage, and model services meet inside a GPU job.远程终端只是起点。把代码版本、任务调度、存储边界和模型服务串起来,才能知道一次计算究竟发生在哪里。端末から GPU ジョブへ。コードのバージョン、実行環境、権限、モデルサービスのつながりをたどる。

Compute / Infrastructure2026.11

Learn to act in imagination, or imagine before acting?在想象中学会行动,还是行动前再想一遍?想像の中で行動を学ぶか、行動の前に想像するか

DreamerV3 and V-JEPA 2-AC both predict the future. One uses predictions to train a policy; the other searches with them before each action.DreamerV3 与 V-JEPA 2-AC 都预测未来,却把预测放在不同位置:前者用它训练策略,后者用它在每次行动前搜索。DreamerV3 は予測から方策を学び、V-JEPA 2-AC は行動のたびに予測を使って探索する。

Illustrated essay交互图解英語・中国語の図解2026.11

How does Genie learn controls without recorded actions?没有按键记录,Genie 怎么学会让世界听指令?操作記録がなくても、Genie はどう操作を学ぶのか

Compress changes between frames into a small codebook, then let the user select a code. Discovering controls from video is different from observing real actions.把相邻画面的变化压进一个小码表,再让使用者选择码字:从视频里发现动作,与知道真实动作,是两回事。フレーム間の変化を小さなコードブックに圧縮し、利用者がコードを選ぶ。映像から得る潜在動作と実際の操作記録を区別する。

Illustrated essay交互图解英語・中国語の図解2026.11

When does a generated video become a useful world model?生成的视频,什么时候才算可用的世界模型?生成映像はいつ使える世界モデルになるのか

Cosmos connects video compression, conditioning and physical evaluation. Visual realism, geometric consistency and correct action consequences impose different requirements.从 Cosmos 的视频压缩、条件接口和物理评测出发,分清画面逼真、几何一致与行动后果正确这三种要求。Cosmos の圧縮、条件入力、物理評価を通じて、見た目の自然さ、幾何的一貫性、行動の結果の正しさを分けて考える。

Illustrated essay交互图解英語・中国語の図解2026.11

Are unseen places reconstructed or imagined?看不见的地方,是重建还是想象?見えていない場所は、復元されたのか、想像されたのか

Atlas organizes images and camera poses into a spatial context. More views constrain generation, but a navigable 3D world is not a fully measured reality.Atlas 把图像与相机位姿组织成空间上下文。更多视角能约束生成,但可漫游的 3D 世界不等于完整测量过的现实。Atlas は画像とカメラ姿勢を空間的な文脈として扱う。視点が増えるほど生成は制約されるが、歩き回れる 3D 世界と実測された現実は同じではない。

Illustrated essay交互图解英語・中国語の図解2026.11

Does a Higher Reward Mean a Better Model?奖励涨了,模型真的变强了吗?報酬が上がれば、モデルは良くなったのか?

Read reward, KL, entropy, policy loss, and validation scores as different measurements—and learn what evidence is needed to connect them.把奖励、KL、熵、策略损失与验证分数放回各自的测量对象,理解一条曲线能回答什么,以及还缺什么证据。報酬、KL、エントロピー、方策損失、検証スコアを、それぞれ何を測る値なのかから読み解く。

Illustrated essay交互图解英語・中国語の図解2026.11

When Better Preference Fitting Makes a Worse Policy偏好拟合得更好,为什么策略反而变差?選好への適合が良くても、方策が悪くなるのはなぜか?

A three-action example reveals how a restricted policy family and pair frequencies can misdirect DPO—and why AuxDPO separates policy movement from preference fitting.从一个三动作算例理解 DPO 的模型错配:策略能表达什么、哪些比较出现得更多,以及 AuxDPO 怎样把两种自由度分开。三つの行動の例から、方策の表現力と比較頻度がDPOをどう制約するか、AuxDPOが何を分離するかを考える。

Illustrated essay交互图解英語・中国語の図解2026.11

Where Do Agent Tasks Come From?Agent 的任务从哪里来?エージェントのタスクはどこから来るのか

OS-Genesis starts with exploration; AgentTrek starts with tutorials. Both must turn a plausible goal into an execution trace that can be checked.从 OS-Genesis 的探索后命题,到 AgentTrek 的教程引导重放:把有意义的目标变成可验证的执行轨迹。探索からタスクを作る OS-Genesis と、チュートリアルを再実行する AgentTrek。もっともらしい目標を、検証できる実行軌跡に変える。

Illustrated essay交互图解英語・中国語の図解2026.11

Why Let an Agent Act Through Code?为什么让 Agent 写代码?なぜエージェントにコードで行動させるのか

CodeAct puts control flow into a program and returns execution feedback to the model. Fewer interactions do not remove the need to verify the result.CodeAct 把控制流交给程序,把环境反馈交还模型。它能压缩交互,但运行成功与任务正确仍是两件事。制御フローはプログラムへ、実行結果はモデルへ。CodeAct は往復を減らせても、動いたことと正しかったことは別である。

Illustrated essay交互图解英語・中国語の図解2026.11

When Should an Agent Think More or Try More?什么时候多想,什么时候多试?いつ深く考え、いつ多く試すべきか

Separate parameter learning, inference-time search and reasoning-mode selection. Spend additional computation where it can change the outcome.把参数训练、推理搜索与思考模式选择分开:同一份预算,应该花在能够改变结果的地方。パラメータ学習、推論時探索、思考モードの選択を分け、結果を変えられる場所に計算量を使う。

Illustrated essay交互图解英語・中国語の図解2026.11

9 月以来的知识整理Knowledge Notes Since September9月からの学習ノート

47 篇完整笔记,按主题重新编排。从强化学习、后训练到 Agent 与世界模型。47 full-length notes on reinforcement learning, post-training, agents, and world models, organized by topic.強化学習、事後学習、Agent、世界モデル。47編のノートをテーマ別に読む。

中文整理Chinese notes中国語ノート2026.11

A³: Assigning Credit to a Sequence of CommandsA³:把一次成败,分给一串命令A³:一連のコマンドに成果を割り当てる

Use command structure to understand per-turn advantages, then separate training gains from observation gains.从命令结构理解逐轮优势,再把训练收益与观测收益分开看。コマンドの構造からターンごとの優位性を理解し、学習と観測の効果を分けて読む。

Chinese explainer交互图解中国語の図解2026.10

Let the Model See Only What Was Known Then让模型只看到当时知道的事その時点で知り得た情報だけをモデルに見せる

Follow time-frozen evidence and conditional calculations through Investor’s Last Exam.沿时间冻结的证据与有条件的计算,理解 Investor’s Last Exam 的评测设计。時点を固定した証拠と条件付き計算から、Investor’s Last Exam の評価設計を読む。

Chinese explainer交互图解中国語の図解2026.10

HarnessPro: Improving How an Agent Works让 Agent 学会省力:HarnessPro 如何进化运行框架HarnessPro:Agent の動かし方を改善する

Trace diagnosis, fixed tests, and Pareto selection through the trade-off between performance and execution cost.沿轨迹诊断、固定测试与 Pareto 选择,理解任务表现和执行成本的取舍。軌跡の診断、固定テスト、Pareto 選択を通じて、性能と実行コストの関係を読む。

Chinese explainer交互图解中国語の図解2026.10

From Cross-Entropy to Preference Learning从交叉熵到偏好学习交差エントロピーから選好学習へ

Connect cross-entropy, Bradley–Terry probabilities, and reward-model gradients through interactive examples.用交互算例串起交叉熵、Bradley–Terry 概率与奖励模型的梯度。交差エントロピー、Bradley–Terry の確率、報酬モデルの勾配を計算例でつなぐ。

Chinese explainer交互图解中国語の図解2026.10

从选择到规划:Bandit 与 MDPFrom Selection to Planning: Bandits and MDPs選択から計画へ:BanditとMDP

从一次选择到连续规划,理解探索、奖励和动作的长期影响。From a single choice to sequential planning: exploration, rewards, and consequences.一度の選択から逐次計画へ。探索、報酬、行動の長期的な影響。

决策基础Decision foundations意思決定の基礎2026.10

Agent 看到的,和环境里发生的What an Agent Sees—and What Actually Happenedエージェントが見るもの、環境で起きたこと

沿一次工具超时,分清环境状态、观察和 Agent 记忆。A tool timeout reveals the difference between state, observation, and agent memory.ツールのタイムアウトから、状態・観測・Agentの記憶を分けて考える。

决策基础Decision foundations意思決定の基礎2026.10

一次 GRPO 更新,究竟学到了什么?Inside a GRPO UpdateGRPOの1回の更新で何を学ぶのか

用四个回答算一次优势,读懂采样、裁剪和策略更新。Four answers make sampling, relative advantages, and policy updates tangible.4つの回答で、サンプリング、相対的な優位性、方策更新を理解する。

模型后训练Post-training事後学習2026.10

GRPO 的改进,改在了哪里?What Changes Beyond GRPO?GRPOの改良はどこを変えるのか

按改动位置比较 DAPO、Dr. GRPO、GSPO 和 CISPO。Locate the changes in DAPO, Dr. GRPO, GSPO, and CISPO.DAPO、Dr. GRPO、GSPO、CISPOが変える箇所を比較する。

模型后训练Post-training事後学習2026.10

模型如何从自己的回答中学习Learning from the Model’s Own Answers自分の回答から学ぶモデル

学生生成,教师反馈:分清 OPSD、OPCD、SDPO 与 KL 方向。Student rollouts and teacher feedback: OPSD, OPCD, SDPO, and KL direction.学生の生成と教師のフィードバック。OPSD、OPCD、SDPOとKLの方向。

模型后训练Post-training事後学習2026.10

让语言模型做选择Turning Language Models into Decision Models言語モデルに選択させる

从候选分数到概率校准,理解 StartLux / Jev 风格的决策接口。Candidate scores, calibration, and StartLux / Jev-style decision interfaces.候補スコア、確率校正、StartLux / Jev型の意思決定インターフェース。

决策模型Decision models意思決定モデル2026.10

先整理线索,再重读长文Collect the Clues, Then Read Again手がかりを整理してから読み直す

把推理轨迹放在原文前面,重新理解长上下文。Place reasoning traces before the source to guide a fresh reading.推論の軌跡を原文より前に置き、再読を導く。

推理与记忆Inference & memory推論と記憶2026.10

模型如何表示物体的位置How Models Represent Where Things Areモデルは物体の位置をどう表すか

从隐藏状态读出空间位置,再分开检验感知与几何推理。Read spatial structure from hidden states; separate perception from geometric reasoning.隠れ状態から空間を読み、知覚と幾何推論を分けて検証する。

模型内部Model internalsモデルの内部2026.10

From Agent Traces to Foundation Model Training DataAgent 轨迹如何变成 Foundation Model 训练数据エージェントの軌跡を基盤モデルの学習データへ

Full conversations, tool protocols, and loss masks—what a row of training data actually contains.完整会话、工具协议与 loss mask:一行训练数据里,模型究竟在学什么。会話全体、ツールの形式、loss mask。学習データの1行から、モデルが学ぶ内容を見る。

Agent training · Data formats2026.10

How an Agent RemembersAgent 是怎么记住事情的エージェントはどう記憶するのか

Follow a fact from storage to the next model call, through retrieval, compression, and session boundaries.从保存到下一次模型调用,图解记忆读取、上下文压缩与会话边界。保存した情報が次のモデル入力に届くまで。検索、文脈圧縮、セッションの境界を図解する。

Agent memory2026.10

An Interactive Blueprint for Agentic Development自动化开发的交互式流程蓝图自動開発のインタラクティブなフローマップ

Explore a shared delivery path, with repair loops, risk gates and human decisions.沿交互流程图探索共用交付链路、返修回路、风险判断与人工介入。共通の実行経路、修復ループ、リスク判断、人の介入を図でたどる。

Interactive system design2026.10

Training Routing Models with Soft Labels用软标签训练路由模型ソフトラベルでルーティングモデルを訓練する

Nimble and KEV experiments on class decisions, probability supervision, and confidence.围绕 Nimble 与 KEV,比较类别判断、概率监督与置信度的训练效果。NimbleとKEVで、クラス判定・確率による教師信号・信頼度を比較する。

Nimble / KEV2026.10

A Visual Guide to Attention注意力机制,按设计拆开看図で読む注意機構

A visual guide to KV sharing, compression, sparse reads, recurrent states, and tiled execution.图解 KV 共享、压缩、稀疏读取、递推状态与分块执行。KV共有・圧縮・疎な読み出し・再帰状態・タイル実行を図で読み解く。

Attention architectures2026.10
To venture into the infinite,
explore the finite in every direction.
若要走向无限,
就向有限的各个方向探寻。
無限へ歩もうとするなら、
有限をあらゆる方角へ探れ。
Goethe · Gott, Gemüt und Welt歌德 · Gott, Gemüt und Weltゲーテ · Gott, Gemüt und Welt

Selected research研究论文研究論文

More publications更多论文その他の論文

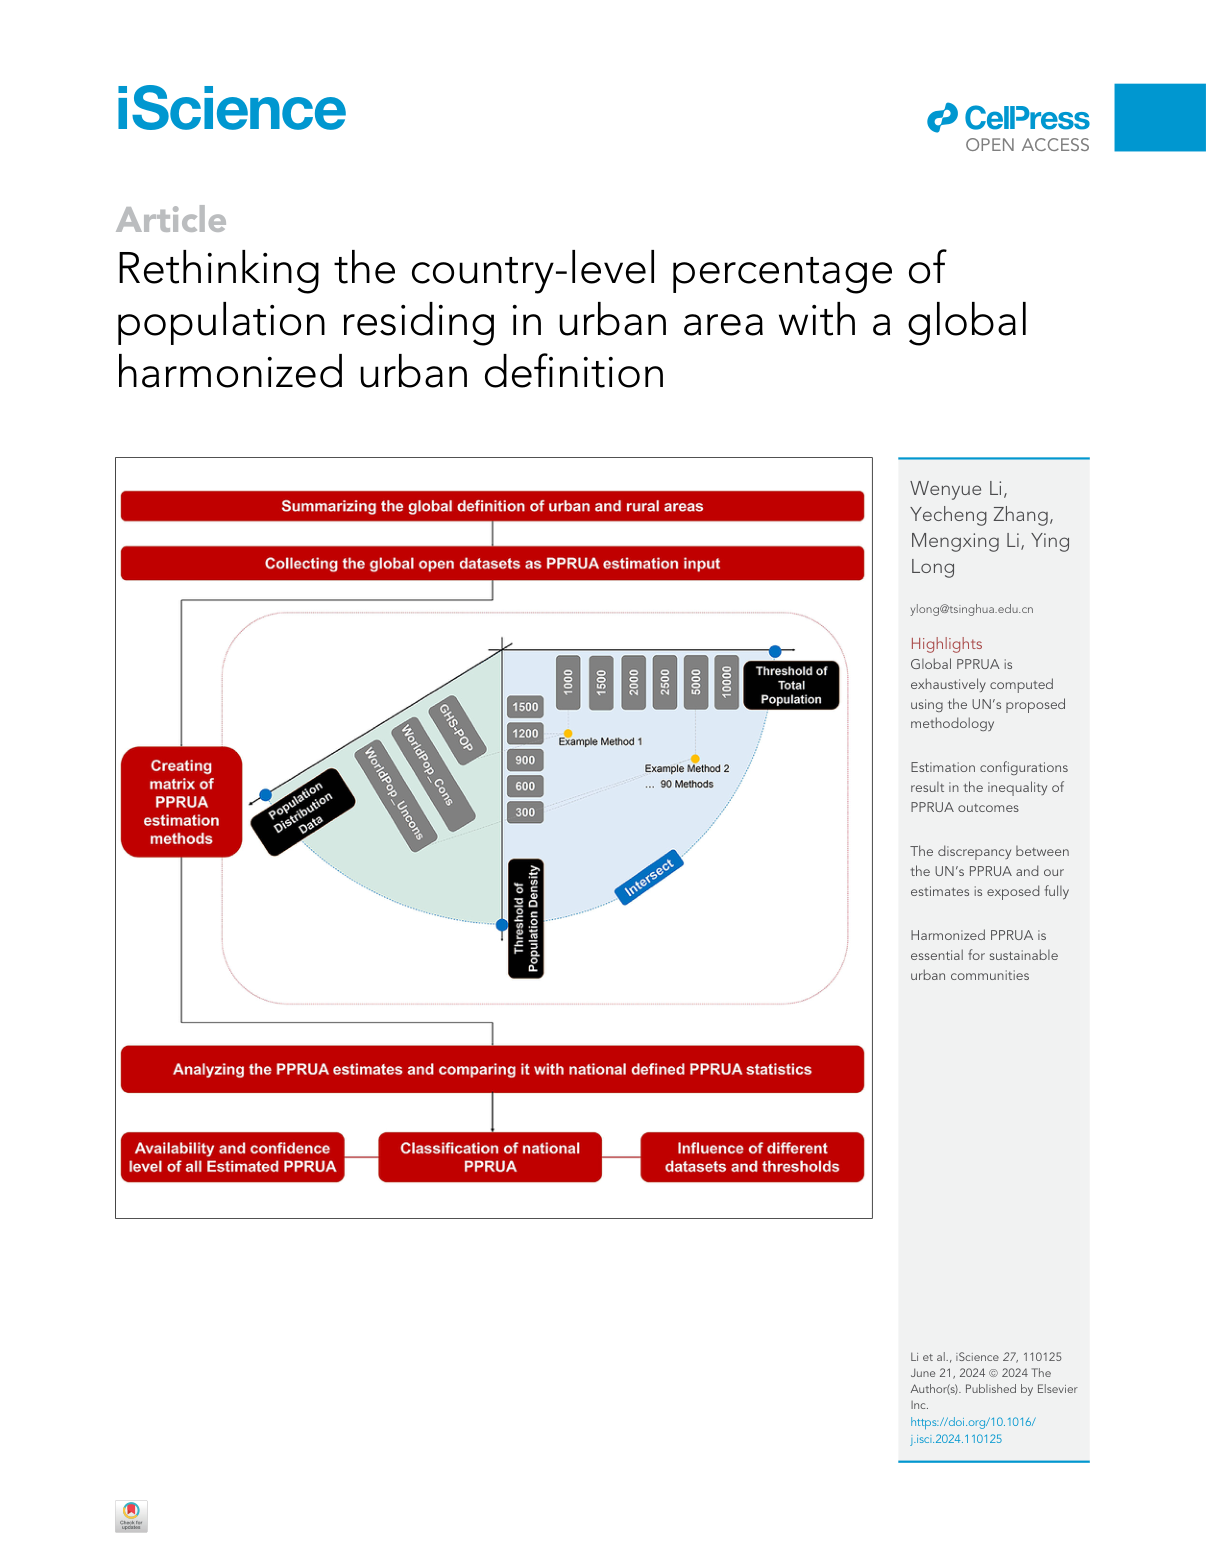
Rethinking the Country-level Percentage of Population Residing in Urban Area with a Global Harmonized Urban Definition

Wenyue Li†, Yecheng Zhang†, Mengxing Li, Ying Long*

iScience, 27, 110125, 2024. DOI | PDF

Details详情詳細
  • Constructed a global harmonized urban definition (GloPPRUA) dataset, providing consistent urban-rural boundaries across countries for comparative urbanization research.
  • 构建全球统一城市定义数据集(GloPPRUA),为跨国城镇化比较研究提供一致的城乡边界划分。
  • 各国間の比較都市化研究のために一貫した都市・農村境界を提供するグローバル統一都市定義データセット(GloPPRUA) を構築。
GloPPRUA

Urban Spatial Risk Prediction and Optimization Analysis of POI based on Deep Learning from the Perspective of an Epidemic

Yecheng Zhang, Qimin Zhang, Yuxuan Zhao, Yunjie Deng, Hao Zheng*

International Journal of Applied Earth Observations and Geoinformation, 112, 102942, 2022. PDF

Details详情詳細
  • Applied GAN-based deep learning for urban spatial risk prediction and POI optimization during epidemic scenarios, combining spatiotemporal modeling with urban planning applications.
  • 应用基于GAN的深度学习进行疫情背景下的城市空间风险预测与POI优化,将时空建模与城市规划应用相结合。
  • GANベースの深層学習を用いて感染症下の都市空間リスク予測とPOI最適化を実施、時空間モデリングと都市計画への応用を融合。
JAG-GAN

WaveC2R: Wavelet-driven Coarse-to-refined Hierarchical Learning for Radar Retrieval

Chunlei Shi, Han Xu, Yinghao Li, Yi-Lin Wei, Yongchao Feng, Yecheng Zhang, Dan Niu

AAAI 2026 (CCF-A). arXiv | PDF

Details详情詳細
  • Satellite-to-radar reflectivity inversion using wavelet-driven coarse-to-refined hierarchical learning framework for meteorological remote sensing.
  • 提出基于小波驱动的粗到精层次学习框架,用于气象遥感中的卫星-雷达反射率反演。
  • 気象リモートセンシングにおける衛星-レーダー反射率反転のためのウェーブレット駆動粗密階層学習フレームワークを提案。
WaveC2R
  • Shi C, Han X, Zhang Y, Wu B, Hou J, Wang J, Niu D. AWFlowS2R: A Flow-Based New Paradigm for All-Weather Satellite-to-Radar Retrieval. arXiv, 2026.
  • Wang L, Hou C, Zhang Y, He J. Measuring Solar Radiation and Spatio-temporal Distribution in Different Street Network Direction through Solar Trajectories and Street View Images. *International Journal of Applied Earth Observation and Geoinformation, 132, 104058, 2024. PDF
  • Long Y, Zhao H, Zhang Y. 新城市科学:技术、计算、变革与应用. *城市规划 CITY PLANNING REVIEW, 48, 2024. DOI | PDF
  • Li Y, Zhang Y, Wu Q, Xue R, Wang X, Si M, Zhang Y. Greening the Concrete Jungle: Unveiling the Co-mitigation of Greenspace Configuration on PM2.5 and Land Surface Temperature with Explanatory Machine Learning. *Urban Forestry & Urban Greening, 88, 128086, 2023. PDF
  • Ding X, Zhang Y, Zhang Y, …, Haick H, Zhang M. Modular Assembly of MXene Frameworks for Noninvasive Disease Diagnosis via Urinary Volatiles. ACS Nano, 16, 17376–17388, 2022. DOI | PDF
  • Yao J, Jian Y, Shen Y, …, Zhang Y. Decoding the Spatial Heterogeneity of Bike-Sharing Impacts. Journal of Urban Planning and Development, 2025. DOI
  • Zhang Y, et al. Generative Design Method of Building Group Based on AIP Assessment. UIA World Congress of Architects, Copenhagen, 2023.
A little spark
can kindle a great flame.
微小的火星,
也能引出大火。
小さな火花から、
大きな炎が生まれる。
Dante · Paradiso I, 34但丁 ·《天堂篇》1.34ダンテ ·『神曲』天国篇 1.34

Open source & projects开源与项目オープンソース・プロジェクト

All projects全部项目すべてのプロジェクト

Research systems研究系统研究システム

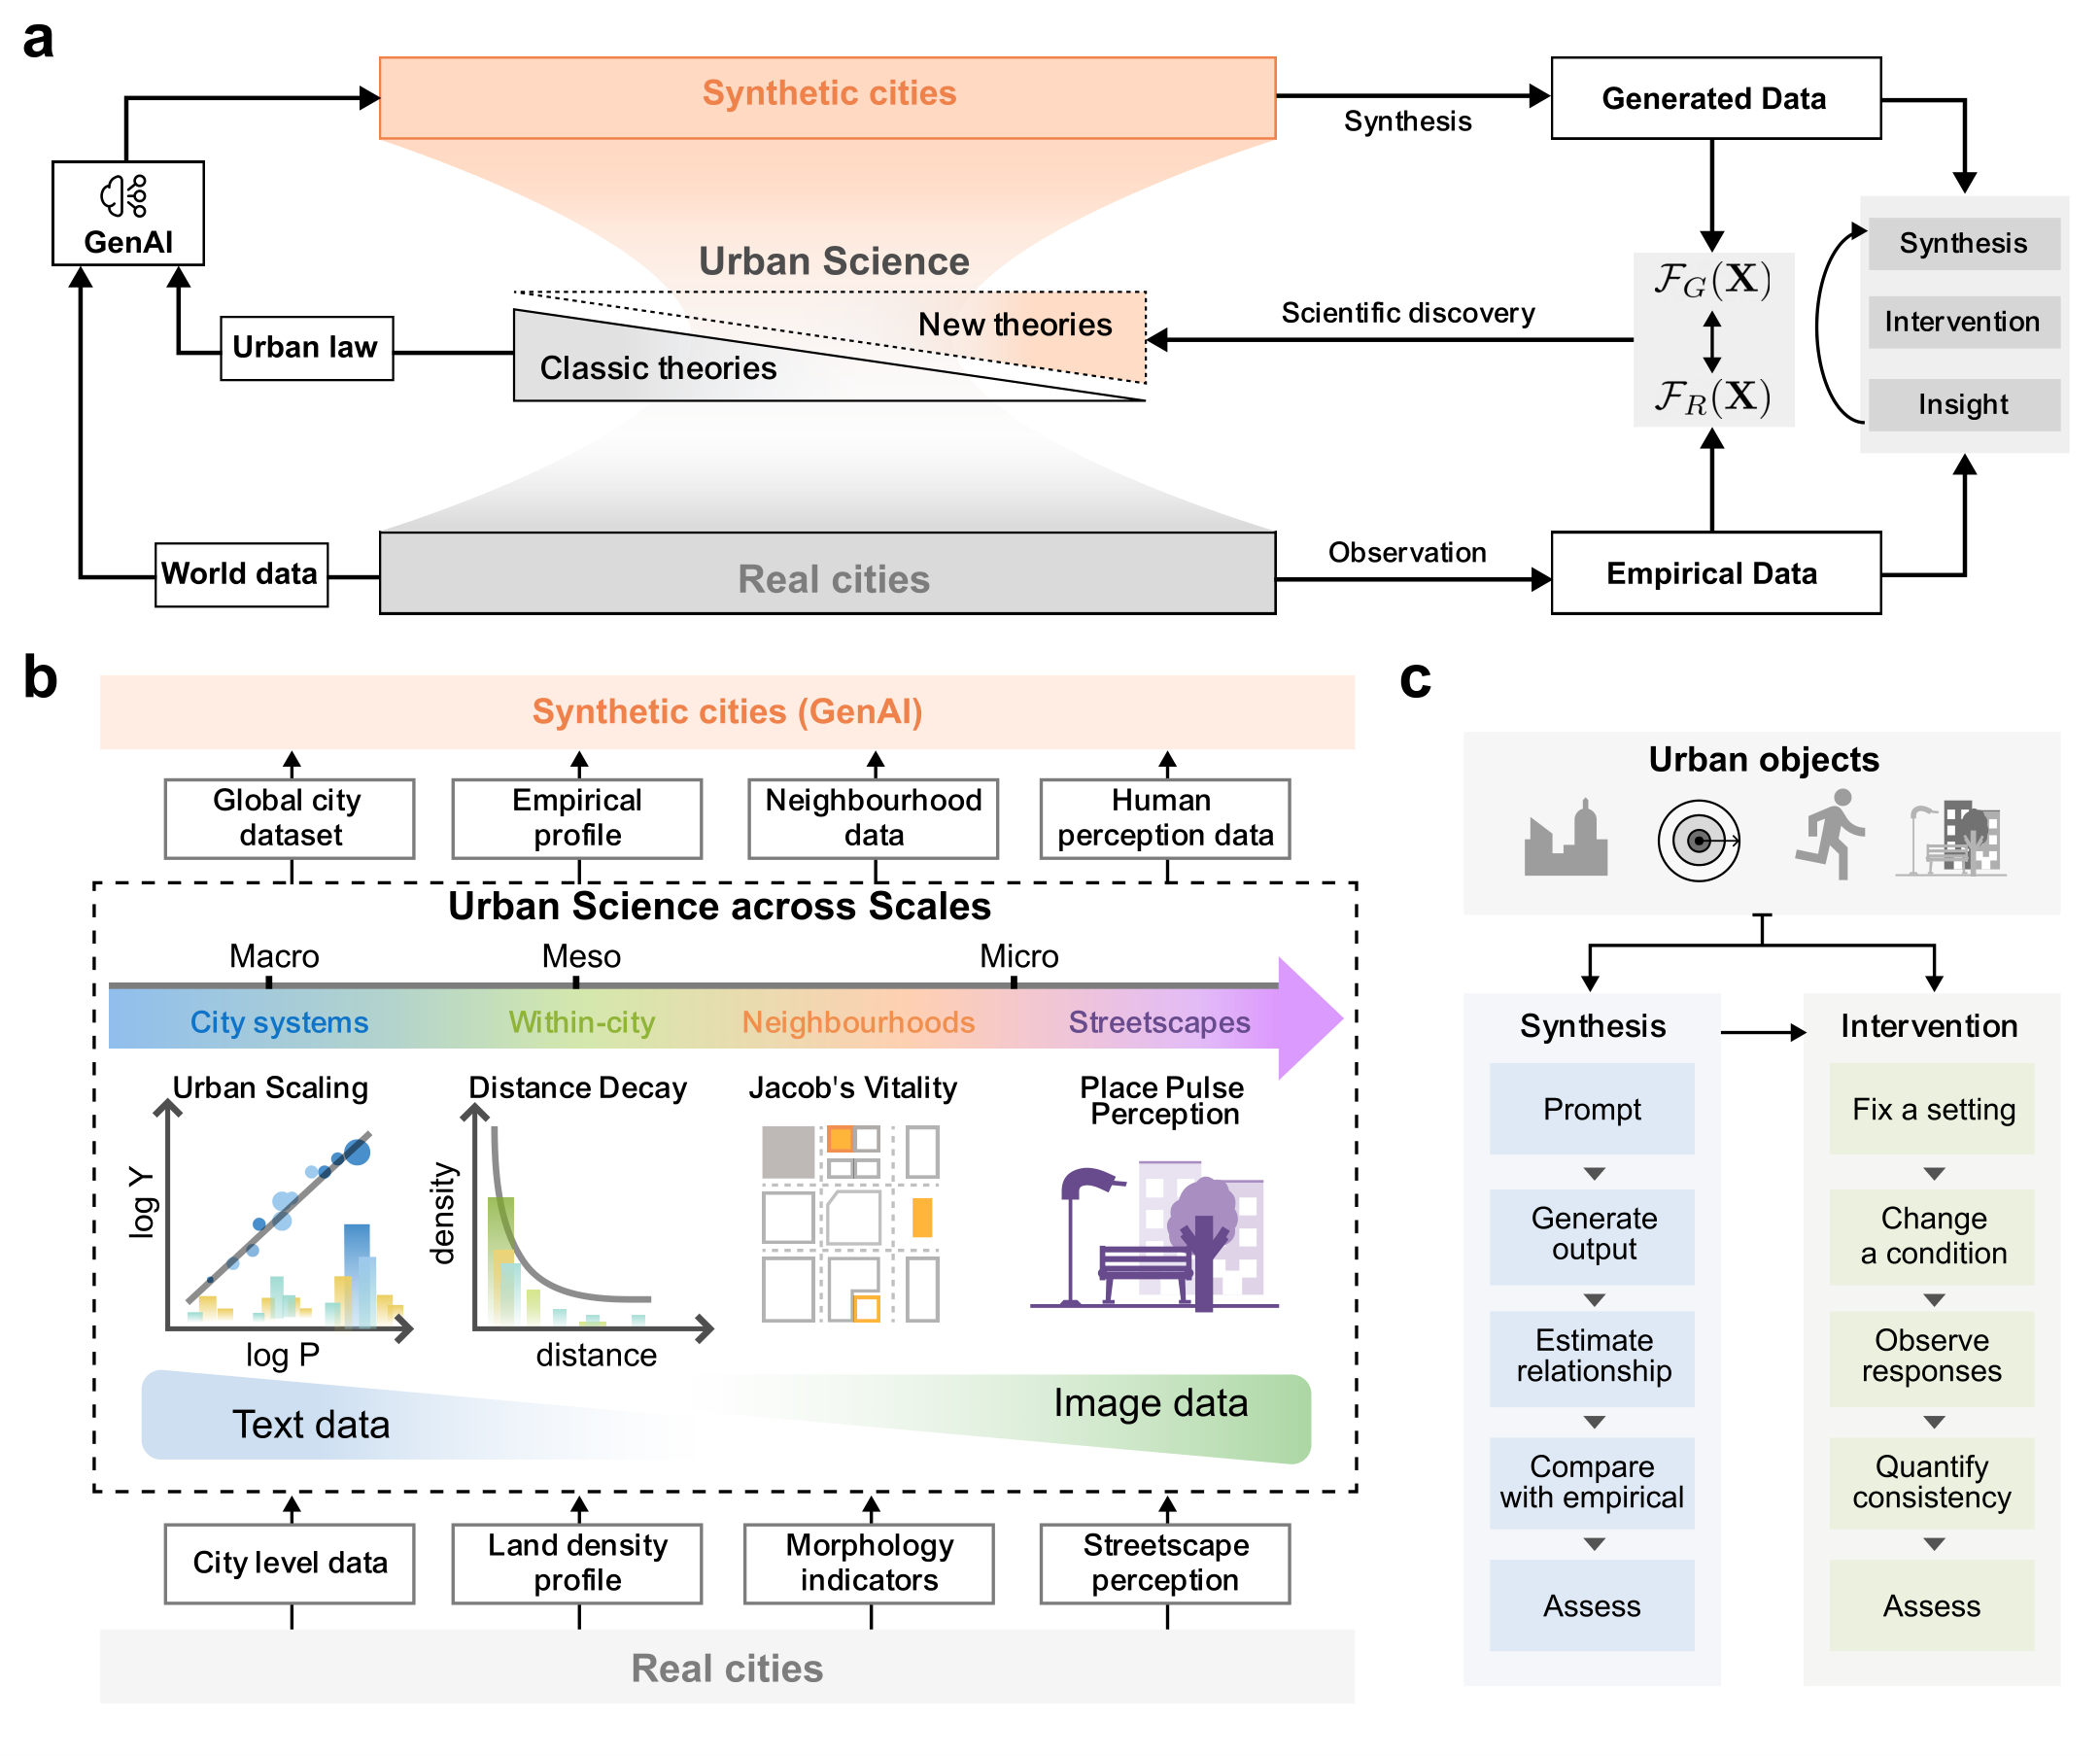
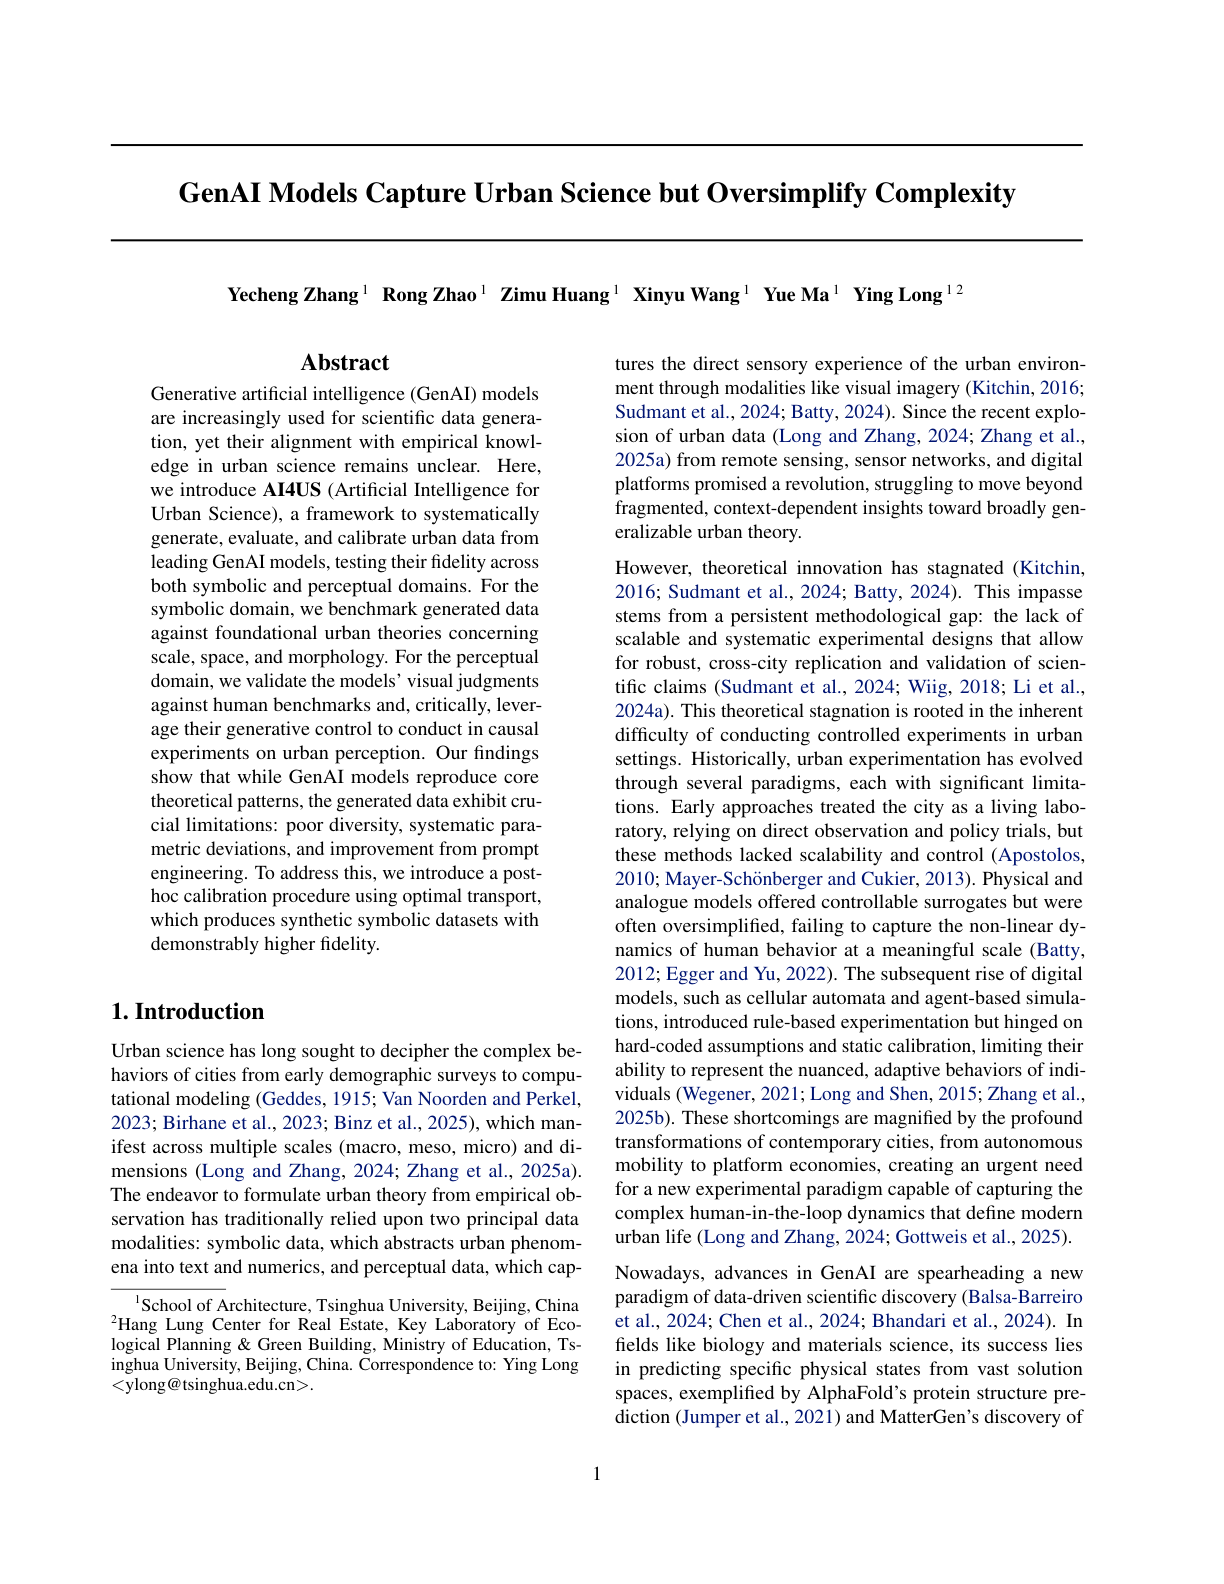
  • Evaluate and calibrate GenAI for urban-science data synthesis.评测并校准生成式AI的城市科学数据合成能力。都市科学データ生成における生成AIを評価・校正。
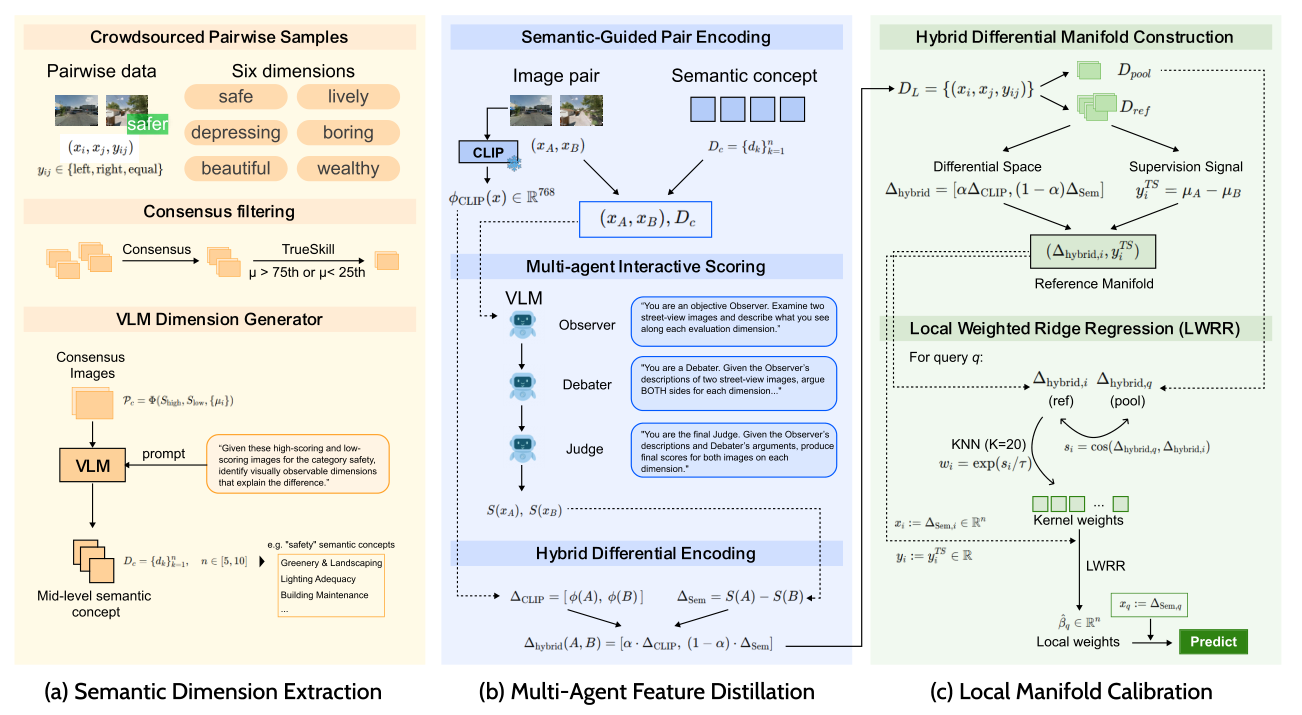
  • Training-free VLM–human preference alignment.免训练的视觉语言模型与人类偏好对齐。学習不要のVLM–人間選好アライメント。

AI productsAI产品AIプロダクト

  • Control coding agents from Feishu, Telegram, or Slack.通过飞书、Telegram或Slack远程控制编程智能体。Feishu、Telegram、Slackからコーディングエージェントを操作。
  • Production engineering-bid intelligence platform for OCR, structured review, retrieval, generation, and audit.面向工程投标的生产级智能审查与生成平台,覆盖OCR、结构化审查、检索、生成与审计。OCR、構造化レビュー、検索、生成、監査を備えた入札インテリジェンス基盤。

Infrastructure and data基础设施与数据基盤とデータ

  • Private model routing, shared-service access, device isolation, and credential-control architecture.私有模型路由、共享服务接入、设备隔离与凭据控制架构。プライベートモデルルーティング、共有サービス接続、デバイス分離、認証情報管理。
  • Restartable historical-imagery routing with actual-date provenance, quality gates, and auditable manifests.支持断点续跑的历史影像路由,记录实际日期、质量门禁与可审计血缘。実取得日、品質ゲート、監査可能なマニフェストを備えた再開可能な歴史画像ルーティング。
  • Local-first personal activity understanding and AI-assisted reflection.Local-first 的个人活动理解与AI辅助反思系统。ローカルファーストな個人活動理解とAI支援リフレクション。

Supporting systems include InfoHub, web-novel-crawler, HomeSync, Desktop Controller, Recall, Prompt Harness, Experiment Log, Note2Video, AI Reviewer, CiteMind, and k2md.配套系统包括 InfoHub、web-novel-crawler、HomeSync、Desktop Controller、Recall、Prompt Harness、Experiment Log、Note2Video、AI Reviewer、CiteMind 与 k2md。関連システムには InfoHub、web-novel-crawler、HomeSync、Desktop Controller、Recall、Prompt Harness、Experiment Log、Note2Video、AI Reviewer、CiteMind、k2md があります。

Explore the complete project catalog →查看完整项目列表 →全プロジェクト一覧を見る →

And so we emerged
to see the stars again.
于是我们走出,
重见群星。
そして外へ出て、
再び星を見た。
Dante · Inferno XXXIV, 139但丁 ·《地狱篇》34.139ダンテ ·『神曲』地獄篇 34.139

Reading阅读読書

Bookshelf →书架 →本棚 →

Technical reports, AI learning, and researchers’ writing.基模技术报告、AI 技术学习与研究者博客。技術レポート、AI 学習、研究者のブログ。

Experience经历経歴

ByteDance · PDI–Seed · Lark Base AI | LLM Algorithm Intern (ByteIntern) | 2026.05 – Present

Nanjing Xinda Institute of Meteorological Science and Technology | Doctoral Practice (Excellent Evaluation) | 2025

Work & methods工作与方法業務・手法
  • Systematically benchmarked 10+ deep learning architectures (CNN/GAN/Diffusion/Transformer/Flow Matching) for FY-4B satellite-to-radar composite reflectivity inversion using 22-channel input (15 base + 7 hand-crafted BTD features encoding cloud phase and moisture gradients); designed exponentially-weighted loss to address extreme class imbalance.
  • Conditional Flow Matching (CFM) achieved CSI +7.2% and FAR -30% over baseline; zero-shot geographic transfer to radar-blind Xinjiang validated with GPM satellite data.

字节跳动 · PDI–Seed · Lark Base AI | 大模型算法实习生(ByteIntern) | 2026.05 – 至今

南京信大气象科学技术研究院 | 博士实践(优秀评价)| 2025

Work & methods工作与方法業務・手法
  • 系统基准测试 10+深度学习架构(CNN/GAN/Diffusion/Transformer/Flow Matching),用于FY-4B卫星-雷达组合反射率反演,使用 22通道输入(15基础通道+7个手工设计BTD特征,编码云相态和水汽梯度);设计指数加权损失函数解决极端类别不平衡问题。
  • 条件流匹配(CFM)在CSI上提升 +7.2%,FAR降低 -30%;实现至无雷达覆盖的新疆地区的零样本地理迁移,使用GPM卫星数据验证。

ByteDance · PDI–Seed · Lark Base AI | LLMアルゴリズムインターン(ByteIntern) | 2026.05 – 現在

南京信大気象科学技術研究院 | 博士実践(優秀評価)| 2025

Work & methods工作与方法業務・手法
  • FY-4B衛星-レーダー合成反射率反転のために 10以上の深層学習アーキテクチャ(CNN/GAN/Diffusion/Transformer/Flow Matching)を体系的にベンチマーク、22チャネル入力(15ベース+7手作りBTD特徴量、雲相と水蒸気勾配をエンコード)を使用;極端なクラス不均衡に対処する指数加重損失を設計。
  • 条件付きフローマッチング(CFM)がCSI +7.2%、FAR -30% の改善を達成;GPM衛星データで検証されたレーダー未カバー地域新疆へのゼロショット地理的転移を実現。

Full resume →完整简历 →履歴書の全文 →

News动态ニュース

Earlier updates往期动态過去のニュース
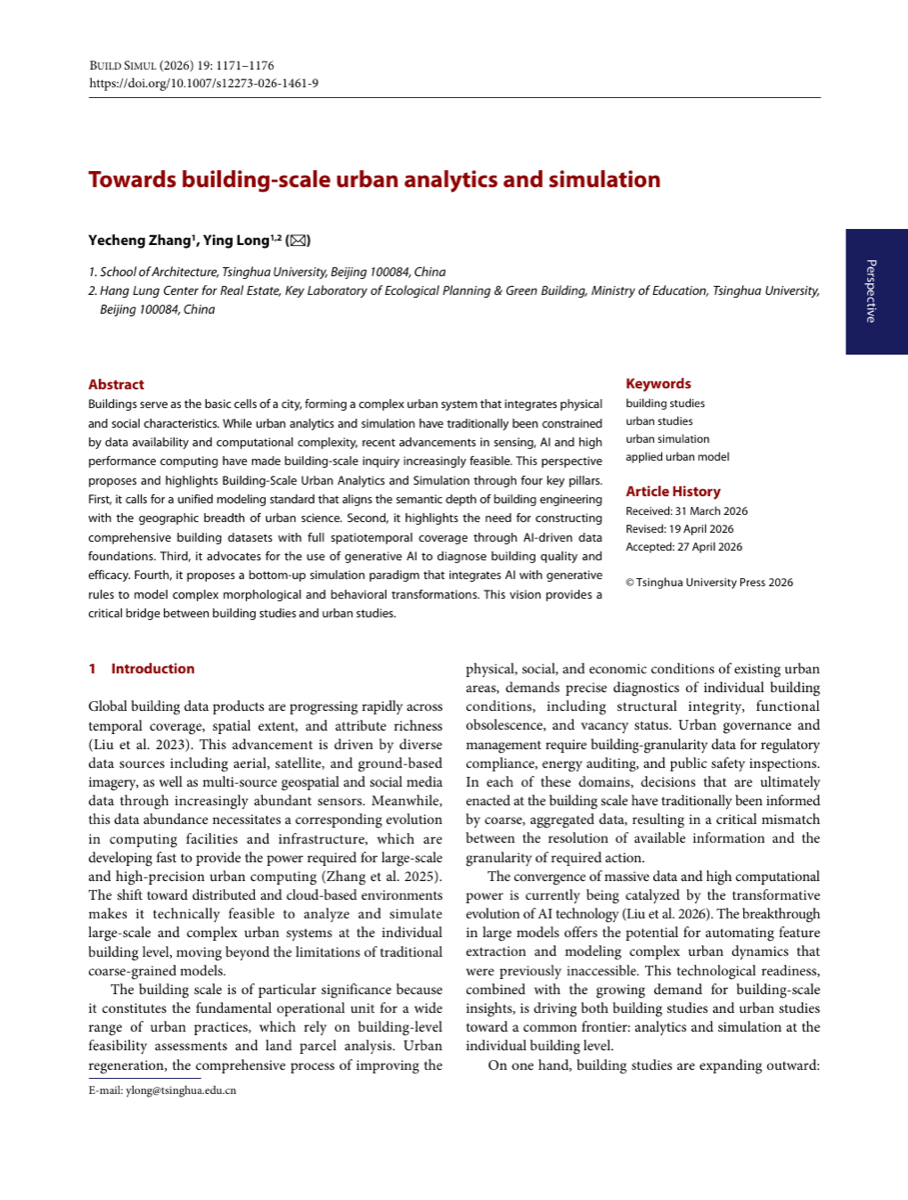
  • 2026.06: Paper “Towards building-scale urban analytics and simulation” published in Building Simulation (SCI Q1).
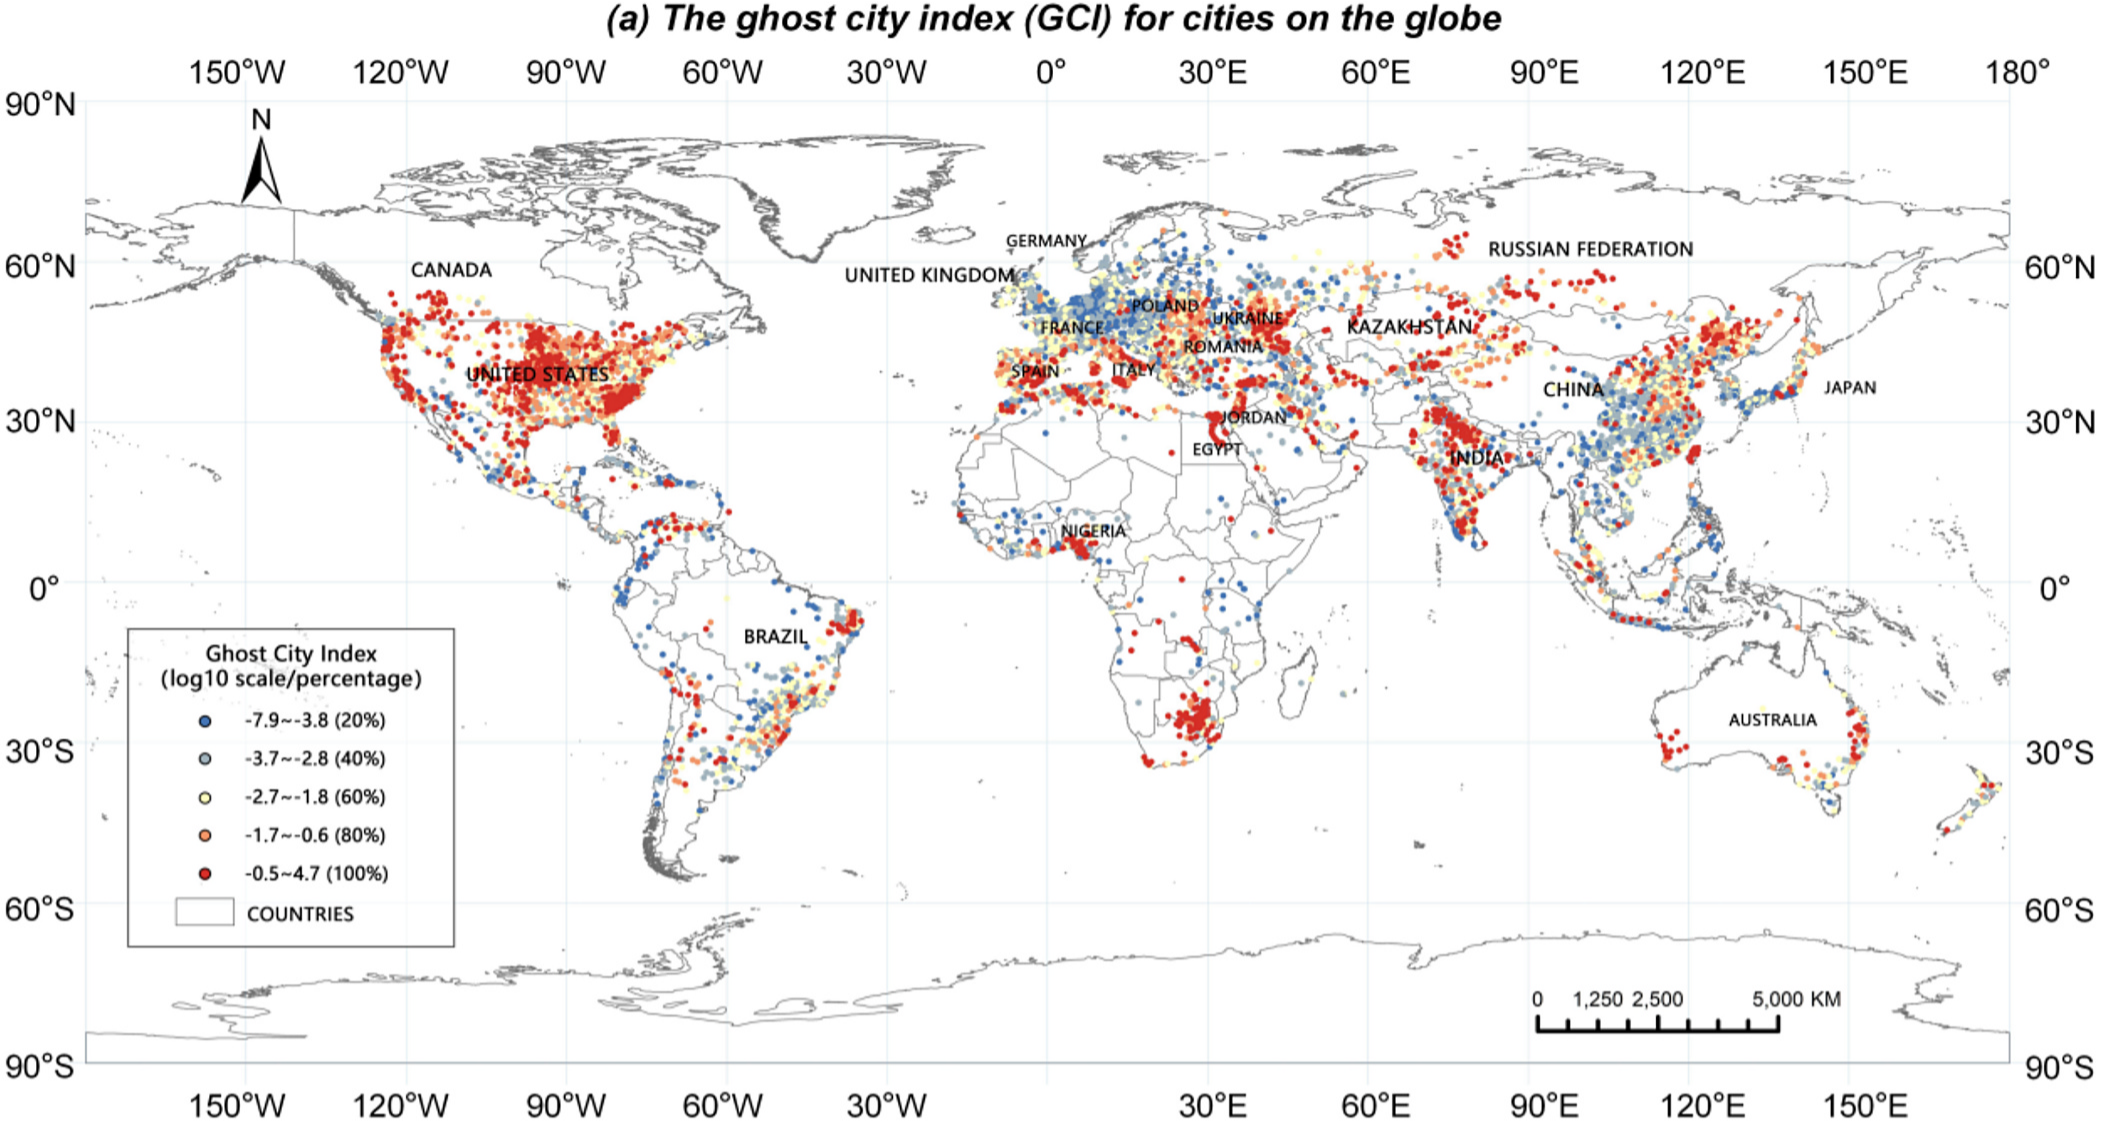
  • 2026.04: Ghost Cities paper recognized as ESI Highly Cited Paper in Social Science, Habitat International.
  • 2026.04: Paper “DAPE: Dual-Stage Parameter-Efficient Fine-Tuning for Consistent Spatial and Temporal Representation” accepted at CVPR 2026 Findings. Project Page
  • 2026.01: Our research on global ghost cities reported by Popular Mechanics (one of the most influential popular science media in the US).
  • 2025.11: Paper “WaveC2R” accepted at AAAI 2026 (CCF-A).
  • 2025.11: CMAB paper recognized as ESI Highly Cited Paper in Geoscience.
  • 2025.11: “新城市科学” paper listed in CNKI Top 20 Most-Cited Papers (2024-2025) in 城市规划 CITY PLANNING REVIEW.
  • 2025.11: Received “GIS Rising Star” Award (10 nationwide) and served as Session Chair & Speaker at the Rising Star Forum, The 13th China College GIS Forum, Shanghai.
  • 2025.10: Poster at China Urban Planning Informatization Annual Conference, Foshan.
  • 2025.10: Received Jin Jingchang Outstanding Paper Award (佳作奖, 22nd edition), Shanghai.
  • 2025.08: Recognized as Outstanding Teaching Assistant (Top 5%) at Tsinghua University, 2024–2025 Fall.
  • 2025.06: CMAB research featured on Tsinghua University’s official Facebook account.
  • 2025.05: Nominated for Tsinghua University’s 29th Graduate “Academic Rising Star” (学术新秀; 10 university-wide, sole nominee from School of Architecture).
  • 2025.05: Exhibitor at China Pavilion, 19th Venice Architecture Biennale, Venice, Italy.
  • 2025.03: Presented at AAG 2025, Detroit, USA.
  • 2025.01: Paper “CMAB” published in Scientific Data — 45,000+ downloads.
  • 2025.01: Received Outstanding Case Award for “AI-Empowered Planning” from Urban Planning Society of China.
  • 2024.12: Paper “Inferring Ghost Cities” published in Habitat International.
  • 2024.11: Presented at Tsinghua University “Future Urban Construction” Ph.D. Forum, Beijing.
  • 2024.06: Invited talk at Applied Urban Modelling (AUM2024), University of Cambridge, UK.
  • 2024.01: Attended NSFC Major Project Kick-off Meeting, Guangzhou.
  • 2023.08: Presented at The First Research Summit of Urban Science, Beijing.
  • 2023.08: Presented at Global Smart Cities Summit (GSCS) & 3rd International Conference on Urban Informatics (ICUI), Hong Kong.
  • 2023.07: Presented at UIA World Congress of Architects, Copenhagen, Denmark.
  • 2023.06: Teaching assistant at Tongji University Architectural DigitalFUTURES workshop “Emerging Planetarism”, Shanghai.
  • 2023.05: Exhibitor at China Pavilion, 18th Venice Architecture Biennale, Venice, Italy.
  • 2022.09: Presented at CUSR Urban Big Data Annual Meeting, Beijing.
  • 2022.07: Presented at 4th International Conference on Computational Design and Robotic Fabrication, Shanghai.
Earlier updates往期动态過去のニュース
  • 2026.06: 论文 “Towards building-scale urban analytics and simulation” 发表于 Building Simulation(SCI Q1)。
  • 2026.04: 鬼城论文入选Social Science领域 ESI高被引论文,Habitat International。
  • 2026.04: 论文 “DAPE: Dual-Stage Parameter-Efficient Fine-Tuning for Consistent Spatial and Temporal Representation” 被 CVPR 2026 Findings 录用。项目主页
  • 2026.01: 全球鬼城研究被美国最具影响力的科普媒体之一 Popular Mechanics 报道。
  • 2025.11: 论文 “WaveC2R” 被 AAAI 2026 (CCF-A) 录用。
  • 2025.11: CMAB论文入选Geoscience领域 ESI高被引论文。
  • 2025.11: “新城市科学”论文入选 中国知网《城市规划》2024-2025年度高被引论文TOP20 榜单。
  • 2025.11: 获2025年第十三届高校GIS论坛‘高校GIS新秀’(全国10人),主持新秀专场论坛并作报告,上海。
  • 2025.10: 在中国城市规划信息化年会展示展板,佛山。
  • 2025.10: 获第22届金经昌城市规划优秀论文佳作奖,上海。
  • 2025.08: 获清华大学2024-2025学年度秋季学期优秀研究生助教(前5%)。
  • 2025.06: CMAB研究成果被清华大学官方Facebook账号推送报道。
  • 2025.05: 获清华大学第二十九届研究生“学术新秀”提名(全校10人,建筑学院唯一推荐)。
  • 2025.05: 参展第19届威尼斯国际建筑双年展中国国家馆,意大利威尼斯。
  • 2025.03: 在2025年美国地理学家协会年会 (AAG 2025) 作报告,美国底特律。
  • 2025.01: 论文 “CMAB” 发表于 Scientific Data — 累计 45,000+次下载。
  • 2025.01: 获中国城市规划学会 “AI赋能规划”优秀案例奖。
  • 2024.12: 论文 “Inferring Ghost Cities” 发表于 Habitat International。
  • 2024.11: 在清华大学“未来城市建设与发展”博士生学术论坛作报告,北京。
  • 2024.06: 受邀在英国剑桥大学 Applied Urban Modelling (AUM2024) 会议作报告。
  • 2024.01: 参加国家自然科学基金委重大项目启动会,广州。
  • 2023.08: 在第一届城市科学大会 (The First Research Summit of Urban Science) 作报告,北京。
  • 2023.08: 在全球智慧城市峰会暨第三届国际城市信息学大会 (GSCS & ICUI) 作报告,中国香港。
  • 2023.07: 在UIA世界建筑师大会作报告,丹麦哥本哈根。
  • 2023.06: 担任同济大学 Architectural DigitalFUTURES workshop “Emerging Planetarism” 助教,上海。
  • 2023.05: 参展第18届威尼斯国际建筑双年展中国国家馆,意大利威尼斯。
  • 2022.09: 在中国城市科学研究会城市大数据专业委员会2022年会作报告,北京。
  • 2022.07: 在第四届国际计算设计和机器人制造会议作报告,上海。
Earlier updates往期动态過去のニュース
  • 2026.06: 論文 “Towards building-scale urban analytics and simulation” が Building Simulation (SCI Q1) に掲載。
  • 2026.04: ゴーストシティ論文が社会科学分野の ESI高被引用論文 に認定、Habitat International。
  • 2026.04: 論文 “DAPE: Dual-Stage Parameter-Efficient Fine-Tuning for Consistent Spatial and Temporal Representation” が CVPR 2026 Findings に採択。プロジェクトページ
  • 2026.01: グローバルゴーストシティ研究が米国の有力科学メディア Popular Mechanics に報道される。
  • 2025.11: 論文 “WaveC2R” が AAAI 2026 (CCF-A) に採択。
  • 2025.11: CMAB論文が地球科学分野の ESI高被引用論文 に認定。
  • 2025.11: “新城市科学”論文が CNKI 被引用数Top20論文(2024-2025)に選出、城市规划。
  • 2025.11: 「GIS新星賞」受賞(全国10名)、第13回中国大学GISフォーラムの新星セッションで座長・発表者を担当、上海。
  • 2025.10: 中国都市計画情報化年次会議にてポスター発表、佛山。
  • 2025.10: 金経昌都市計画優秀論文賞(第22回)受賞、上海。
  • 2025.08: 清華大学 優秀ティーチングアシスタント(上位5%、2024–2025秋学期)に認定。
  • 2025.06: CMAB研究が清華大学公式Facebookアカウントで紹介。
  • 2025.05: 清華大学第29回大学院生「学術新星」候補に推薦(全学10名、建築学院唯一の推薦)。
  • 2025.05: 第19回ヴェネチア・ビエンナーレ国際建築展 中国館に出展、イタリア・ヴェネチア。
  • 2025.03: AAG 2025(米国地理学者協会年次総会)にて発表、米国デトロイト。
  • 2025.01: 論文 “CMAB” が Scientific Data に掲載 — 45,000回以上ダウンロード。
  • 2025.01: 中国都市計画学会より 「AI活用計画」優秀事例賞 を受賞。
  • 2024.12: 論文 “Inferring Ghost Cities” が Habitat International に掲載。
  • 2024.11: 清華大学「未来都市建設」博士課程フォーラムにて発表、北京。
  • 2024.06: 英国ケンブリッジ大学 Applied Urban Modelling (AUM2024) にて招待講演。
  • 2024.01: 国家自然科学基金委員会重大プロジェクトキックオフ会議に参加、広州。
  • 2023.08: 第1回都市科学研究サミット (The First Research Summit of Urban Science) にて発表、北京。
  • 2023.08: グローバルスマートシティサミット (GSCS) & 第3回国際都市情報学会議 (ICUI) にて発表、香港。
  • 2023.07: UIA世界建築家会議にて発表、デンマーク・コペンハーゲン。
  • 2023.06: 同済大学 Architectural DigitalFUTURES ワークショップ “Emerging Planetarism” にてティーチングアシスタント、上海。
  • 2023.05: 第18回ヴェネチア・ビエンナーレ国際建築展 中国館に出展、イタリア・ヴェネチア。
  • 2022.09: 中国都市科学研究会都市ビッグデータ委員会2022年次会議にて発表、北京。
  • 2022.07: 第4回国際コンピュテーショナルデザイン・ロボティックファブリケーション会議にて発表、上海。
Review history审稿记录査読の記録
  • 2023–present: Invited Reviewer, Cities and Computers, Environment and Urban Systems (Elsevier).
  • 2024–present: Invited Reviewer, Nature Cities, Scientific Data, and npj Urban Sustainability (Nature Portfolio).
  • 2025–present: Invited Reviewer, Verixiv.
  • 2023–至今:受邀担任 Cities、Computers, Environment and Urban Systems(Elsevier)审稿人。
  • 2024–至今:受邀担任 Nature Cities、Scientific Data、npj Urban Sustainability(Nature Portfolio)审稿人。
  • 2025–至今:受邀担任 Verixiv 审稿人。
  • 2023–現在:Cities、Computers, Environment and Urban Systems(Elsevier)の招待査読者。
  • 2024–現在:Nature Cities、Scientific Data、npj Urban Sustainability(Nature Portfolio)の招待査読者。
  • 2025–現在:Verixiv の招待査読者。
Open datasets开放数据集オープンデータ
  • CMAB — China’s Multi-Attribute Building Dataset (32M+ buildings, 45,000+ downloads, ESI Highly Cited). Dataset
  • GloGCI — Global Ghost City Index (10,000+ cities worldwide, 4,000+ downloads).
  • GloPPRUA — Global Harmonized Urban Definition.
  • AI4US — Generative AI Benchmarks for Urban Science (2,000+ downloads).
  • CMAB — 中国多属性建筑数据集(3200万+栋建筑,45,000+次下载,ESI高被引)。数据集
  • GloGCI — 全球鬼城指数(覆盖全球10,000+城市,4,000+次下载)。
  • GloPPRUA — 全球统一城市定义数据集。
  • AI4US — 城市科学生成式AI评测基准(2,000+次下载)。
  • CMAB — 中国多属性建物データセット(3,200万棟以上、45,000回以上ダウンロード、ESI高被引用)。データセット
  • GloGCI — グローバルゴーストシティ指数(世界10,000都市以上、4,000回以上ダウンロード)。
  • GloPPRUA — グローバル統一都市定義データセット。
  • AI4US — 都市科学のための生成AIベンチマーク(2,000回以上ダウンロード)。

Writing activity写作动态執筆の更新